Fixed-Wing UAV Capstone
A 7-foot-wingspan, approximately 5 kg fixed-wing UAV designed, built, and flight-tested as a six-month high-school capstone by a three-person team that I led.
- SPAN 7 FT
- AIRFRAME ~5 KG
- INTENDED PAYLOAD ~5 KG
- AIRFOIL NACA 4412

Objective
Design, build, and test a 7-foot-wingspan fixed-wing UAV for an approximately 5 kg intended payload, meeting the capstone's test requirements.
What I made
- Designed the wings, electronics bay, and V-tail configuration.
- Modeled a four-piece snap-together 3D-printed V-tail with flexible TPU print-in-place hinges, plus 3D-printed wingtips.
- Used Autodesk CFD to compare lift and drag behavior, estimate ideal-condition flight time and lift capacity, and inform a wing extension, nose rework, and NACA 4412 airfoil selection.
- Built the vacuum formers myself, including designing and tuning their heating element.
- Designed the mold-making process and carried out the vacuum forming, changing the skin to vacuum-formed PETG to reduce material use, weight, and fabrication time.
- Diagnosed a center-of-mass measurement error during testing and moved the wings forward to improve stability.
Process & iteration
The airframe was built around a carbon-fiber rod with laser-cut balsa ribs and a vacuum-formed skin. Early skin prototypes were vacuum-formed over a peg-board mold; later iterations moved to PETG sheet, and the final airframe skin was vacuum-formed over a steel-mesh surface with a supported forming method (see the vacuum-forming matrix in Evidence). The forming machines themselves have their own page: Vacuum formers.
I used Autodesk CFD to simulate the airframe in flight and find the magnitudes of the force vectors acting on it. I used those results to make the necessary adjustments: a wing extension, a reworked nose, and selection of the NACA 4412 airfoil. Development also included bench-thrust testing, spar-flex testing, and diagnosis of a center-of-mass measurement error that was corrected by moving the wings forward, ahead of the flight described in Result.

Evidence
Vacuum-forming iteration matrix
| Version | Vacuum surface | Plastic used | Mold design | Plastic lower method | Form quality | Degree of mold degradation | Form consistency |
|---|---|---|---|---|---|---|---|
| Prototype 1 | Peg board | PVC | 3D print | Manual, unsupported | Med | High | Med |
| Prototype 2 | Peg board | PVC | 3D print, plaster fill | Manual, unsupported | Med | Low | Med |
| Prototype 3 | Peg board, more holes | PETG | 3D print, plaster fill | Manual, unsupported | Med | Low | Med |
| Prototype 4 | Peg board, more holes | PETG | 3D print, plaster fill | Manual, unsupported | Med | Low | Med |
| Final | Steel mesh | PETG | 3D print, plaster fill | Manual, supported | High | Low | High |
View the original spreadsheet screenshot
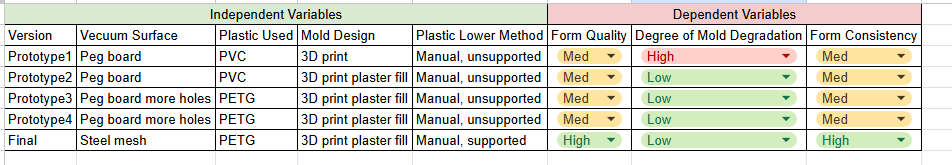
The vacuum-forming matrix shows the prototypes moving from PVC to PETG and from a peg-board to a steel-mesh vacuum surface across five iterations; the final entry rates high for form quality and consistency and low for mold degradation.
Limitations
This table is transcribed directly from the original spreadsheet screenshot linked above. The "Vacuum surface" column heading corrects a typo in the source image's own header text; no other values are altered.


Result
The aircraft achieved a short successful flight that met the capstone's test requirements. The project was not extended into a longer flight-test campaign after the school project ended.